Experiments
Eight experiments, each with a committed artifact. Numbers here are mirrored in results, which is generated from those artifacts.
E3, the failure measured
Three ways to differentiate the same bouncing ball: grid-reset autodiff (exactly 0.0 at every step size), the interpolated-event repair (converging but erratic, and itself hand-implemented event sensitivity), and the saltation endpoint (exact at any step size). See the problem.
E1, inverse design
Optimize launch velocity and restitution so the ball lands in a cup 1.1 m past
where the initial guess settles, every Adam step one jax.grad through both
Tesseracts.
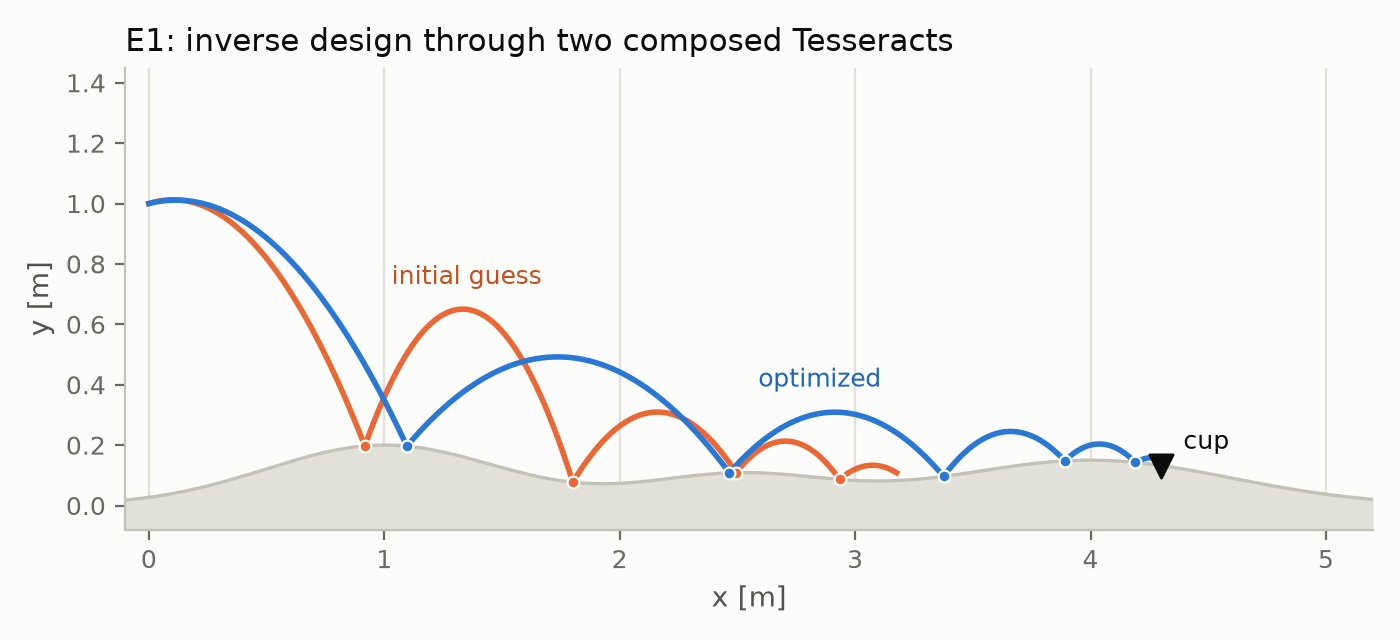
Plotted from e1_history.npy and e1_params_history.npy by make_figures.py.
Miss falls from 1.12 m to 2.7 cm through five impacts. The optimizer crosses bounce-count boundaries on the way (4, 6, 5, with excursions to 8). The objective is discontinuous at those crossings, which is inherent to contact; the fixed-topology gradients on each side are exact, and that is what carries Adam through.
E2 and E2b, calibration
Recover material parameters (e, μ) from the positions of three impacts
observed with 5 mm noise, an observable that exists only because of events.
Point estimation recovers e to 0.002 and μ to 0.009. For the posterior,
NumPyro NUTS runs against the containerized solver: 23,440 leapfrog steps
across two chains in the sampling phase, each an apply plus a saltation VJP
over HTTP, with warmup and sampling together taking about 23 minutes. Zero divergences, split r-hat 1.01 on two chains, which is a weak check
rather than a passed one, with an effective sample size of 344 and 330 from
2000 draws,
e = 0.697 ± 0.007 and μ = 0.096 ± 0.009, with the truth inside both
credible intervals.
The container is load-bearing rather than packaging here. NumPyro’s jitted callbacks run off the main thread, which an in-process embedded Julia runtime does not tolerate; over HTTP the problem does not arise. Reported upstream as tesseract-jax#234.
E4, terrain design
The terrain parameters are differentiable inputs, so the structure itself becomes the design variable. One terrain routes balls entering at 1.6 and 2.6 m/s to two different cups, miss falling from 2.88 m and 0.48 m to 2.2 and 3.0 cm.
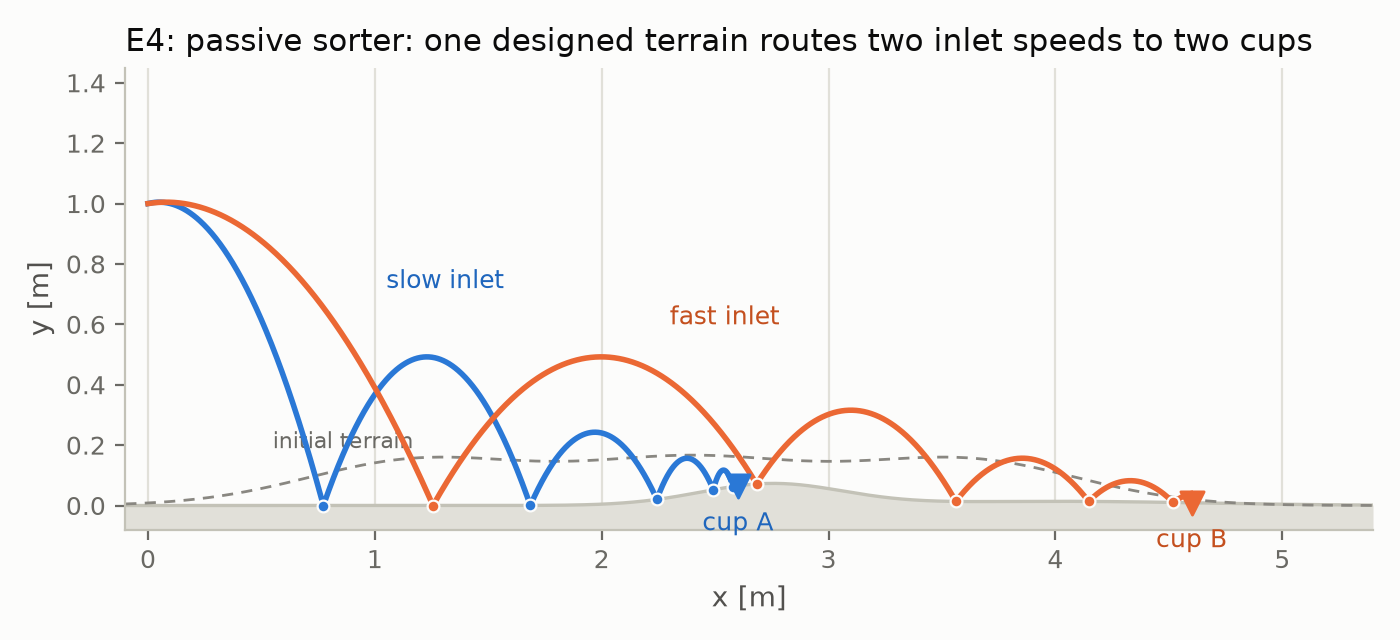
Plotted from e4_result.npz by make_figures.py.
E5, the 24-dimensional separator
Resilience separators sort particles by how far they bounce off a profiled hard surface. USDA Agriculture Handbook 354 (1968) describes one as “a long inclined plane interrupted with several bounce plates”, and bounce rollers are sold today to separate potatoes from stones.
Two particles enter identically and differ only in restitution, e = 0.5 and
e = 0.8. The design vector is the 24 bump amplitudes of the surface, and
each particle must land in its own bin.
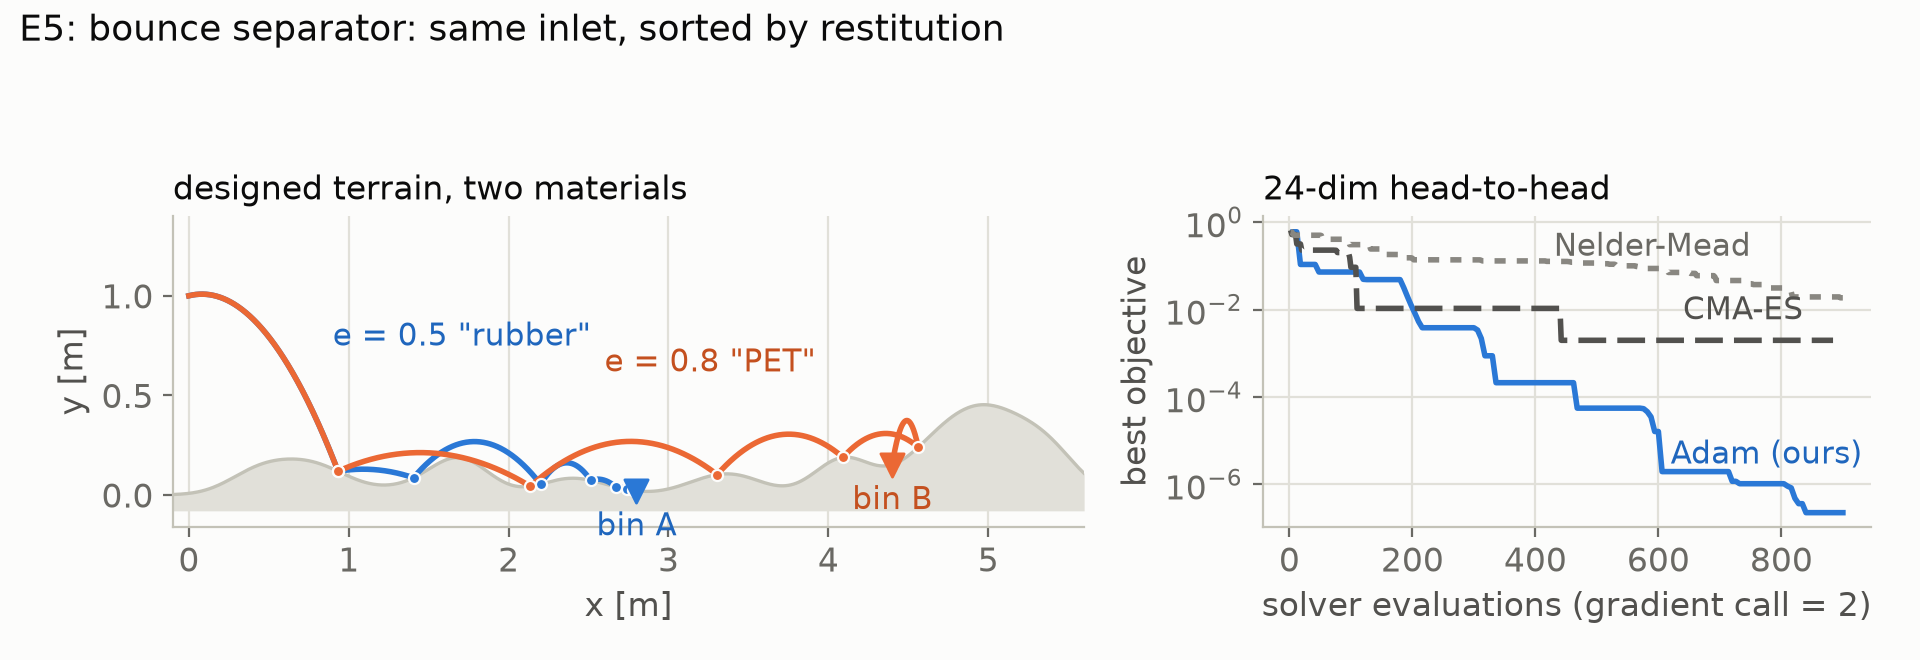
Plotted from e5_result.npz by make_e5_figure.py.
Landing errors of 0.23 mm and 0.42 mm.
Two caveats, both about where the run stops. The two particles do not stop
under the same rule: the low-restitution one exhausts the eight-impact budget
and the high-restitution one reaches t_final, so the objective compares
position-at-the-eighth-impact against position-at-a-fixed-time. And the design
is defined at its own horizon: evaluated at t_final = 3.0 instead of 2.2 the
trained e = 0.8 particle lands 0.67 m from its target rather than 0.4 mm.
The first caveat is the one any fixed-length chute shares: the low-restitution particle is stopped by the event
budget rather than by coming to rest, so the separation surface is “position
after eight impacts”, not “position at rest”.
For the method comparison, see the multi-seed benchmark in verification studies, which supersedes the single-run figure above.
E5b, design under uncertainty
Real separators process streams with scatter. The design objective becomes the expected landing loss over an ensemble with inlet-velocity and per-particle restitution scatter, with fixed common random numbers so the ensemble gradient is exact. Statistics in studies.
E6, zero-shot generalization
The E5 surface was optimized for exactly two restitution values. Sweeping the
continuum it never saw, the geometry acts as a classifier: everything in
e ∈ [0.35, 0.875] is binned by a single threshold.
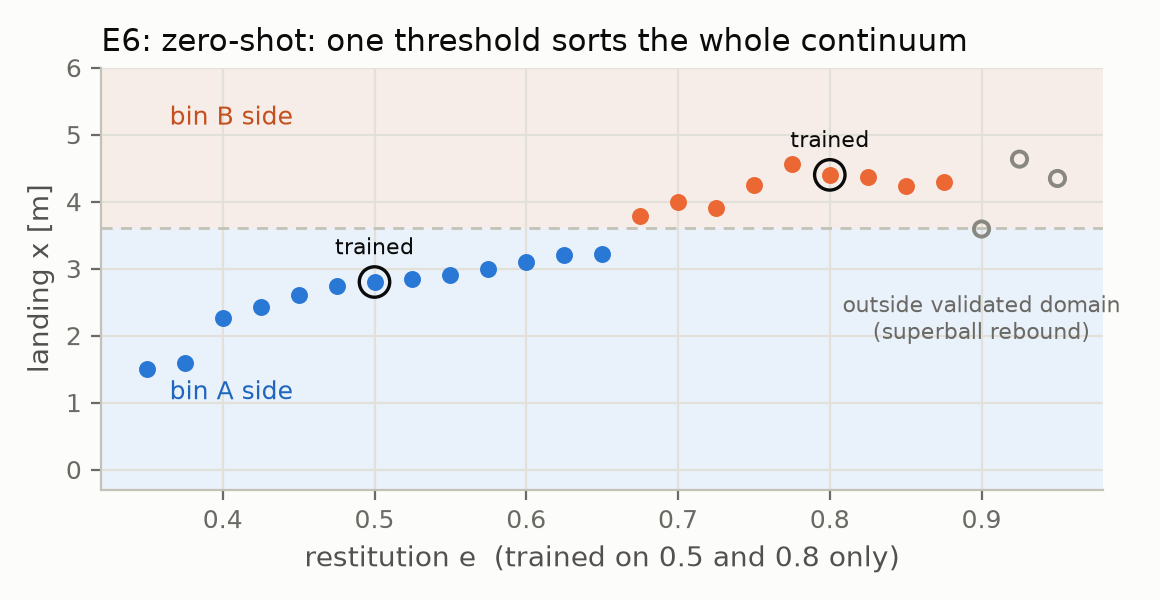
Plotted from e6_result.npz by make_figures.py.
The binning quantity is where the run ends, which for most in-domain points is
the event-capacity truncation rather than a settled rest position, so the
classifier is “which side after eight impacts”. Beyond e ≈ 0.9
classification stops being clean, and the jitter study in
studies shows the point design is less decisive than this
deterministic sweep suggests.